Description
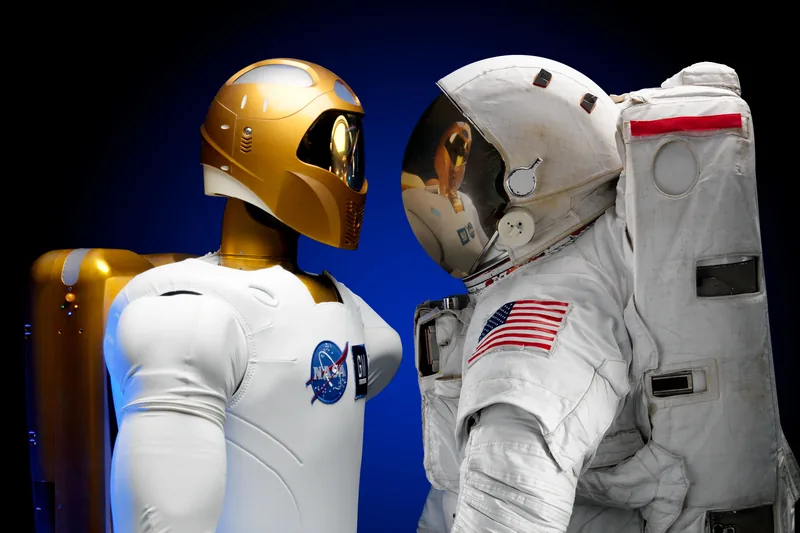
Robonaut 2 (R2) is a dexterous humanoid developed by NASA Johnson Space Center with General Motors under a 2007 Space Act Agreement, revealed in February 2010 and launched to the International Space Station in 2011 as the first humanoid robot in space. It was initially deployed as a torso-only humanoid mounted on a stanchion; each 7-DoF arm can hold 20 lb in any pose in Earth gravity, and its arms move at up to 2 m/s.
humanoidresearchdual-armteleoperationmanipulationhistorical
Specifications
| Hands | 5-finger dexterous hands |
| Payload | 9 kg |
| Release Date | 2010 |