Description
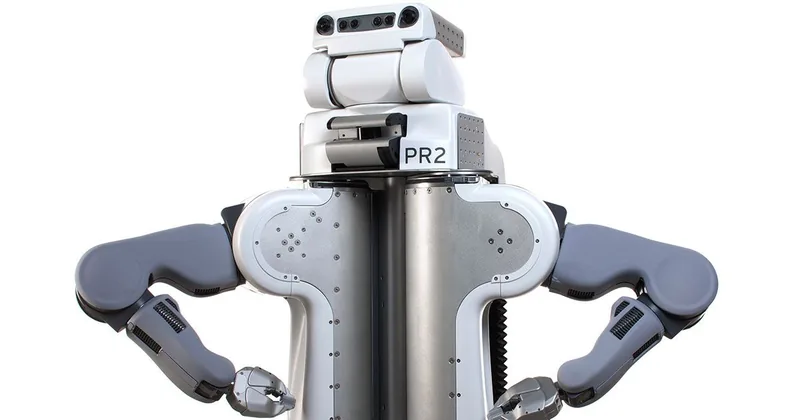
PR2 (Personal Robot 2) is a wheeled two-armed research robot developed by Willow Garage alongside the open-source ROS framework. It became available for purchase in September 2010 and carries stereo cameras, a Kinect, tilting Hokuyo laser scanners, fingertip pressure sensors and a telescoping spine; Willow Garage has since closed.
researchmobile-manipulatordual-armrosopen-sourcedev-platformwheeledhistoricaldiscontinued
Specifications
| Weight | 226.8 kg |
| Size | 66.8 x 66.8 x 165 cm (spine extended) |
| Hands | two-finger grippers |
| Degrees of Freedom | 20 |
| Speed | 3.6 km/h |
| Release Date | 2010 |