Product highlights
- Named xArm 5 has 5 arm axes, 3 kg maximum payload, 700 mm reach, 1 m/s maximum TCP speed and ±0.1 mm repeatability. Joint angular speed 180°/s is a separate measurement; repeatability is not absolute positioning accuracy.
- Current named-model table and 1305 hardware manual give 11.3 kg arm-only mass. The support comparison instead gives 11.2 kg; exact historical revision/configuration mapping is not established, so the discrepancy is retained.
- The support article calls its five-axis column xArm 5 Lite and explicitly limits flexible Cartesian control to x/y/z/yaw with the flange parallel to the base. Five mechanical axes do not imply arbitrary six-dimensional poses; no duplicate Lite hardware card is inferred.
- Python/C++ SDKs, ROS/ROS 2, hand-guided teaching and browser-hosted UFACTORY Studio support integration. Simulation compatibility, external vision, grippers and a six-axis force/torque sensor remain separate software/tooling options.
- Collision detection compares measured joint current with a dynamic model. Payload, center of mass, mounting direction and friction parameters affect triggering; this is not an included six-axis force sensor or an independently certified contact-force limit.
- Current 1305 model codes are XF1305, XI1305 and XS1305. Controller masses/dimensions and Gripper G2 IP40 remain component data; the family’s 2018 introduction and varying starting prices do not establish this model’s first sale year or exact package price.
Product sources
- UFACTORY — manufacturer manual/technical sheet · Manufacturer source · Checked 2026-11-02
- UFACTORY — manufacturer manual/technical sheet · Manufacturer source · Checked 2026-11-02
- UFACTORY — manufacturer product/support information · Manufacturer source · Checked 2026-11-02
- UFACTORY — manufacturer product/support information · Manufacturer source · Checked 2026-11-02
- UFACTORY — manufacturer product/support information · Manufacturer source · Checked 2026-11-02
Description
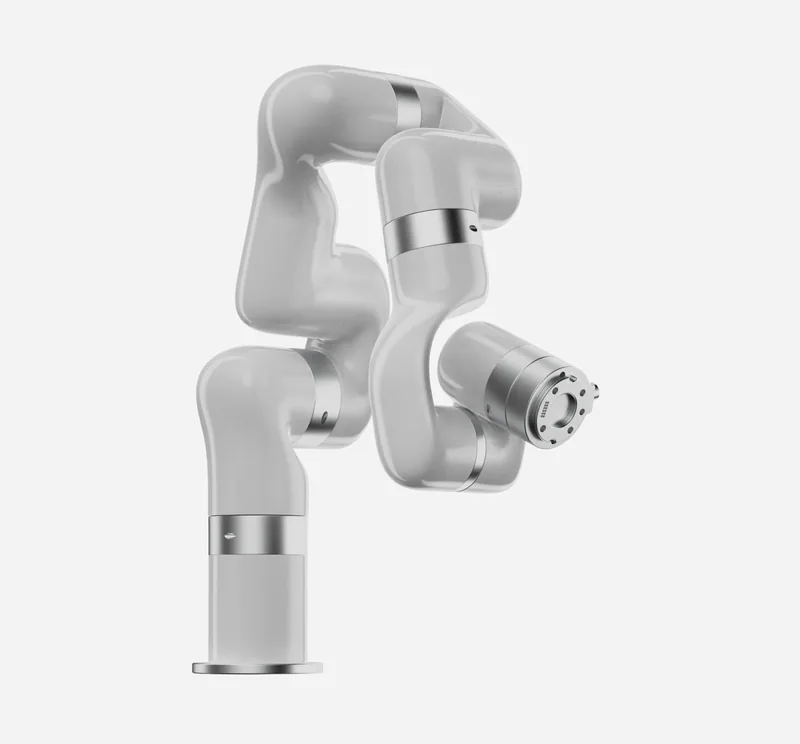
xArm 5 is the separately named 5-axis UFACTORY arm with 3 kg maximum payload, 700 mm reach, 1 m/s maximum TCP speed and ±0.1 mm repeatability. Current 1305 documentation and the support comparison disagree on arm-only mass. Studio and open SDK/ROS interfaces support integration; tools, controller choice and installation-dependent collision detection retain their scope.
industrialcobotprogrammablerosdev-platform
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| PriceSource review · | Not disclosed |
| WeightSource review · | 11.3 kg in current 1305 manual/sheet; support comparison 11.2 kg; revision mapping unresolved |
| Arm reachSource review · | 700 mm reach; not robot envelope or total span |
| Arm repeatabilitySource review · | ±0.1 mm manufacturer repeatability; not absolute accuracy |
| HandsSource review · | External flange tooling; gripper/vacuum/F-T sensor package not established |
| Degrees of FreedomSource review · | 5 mechanical arm axes; Cartesian flexible motion limited to x/y/z/yaw per support guide |
| PayloadSource review · | 3 kg maximum; actual allowable load depends on TCP offset |
| SpeedSource review · | 1 m/s maximum TCP linear speed; 180°/s maximum joint speed is separate |