Product highlights
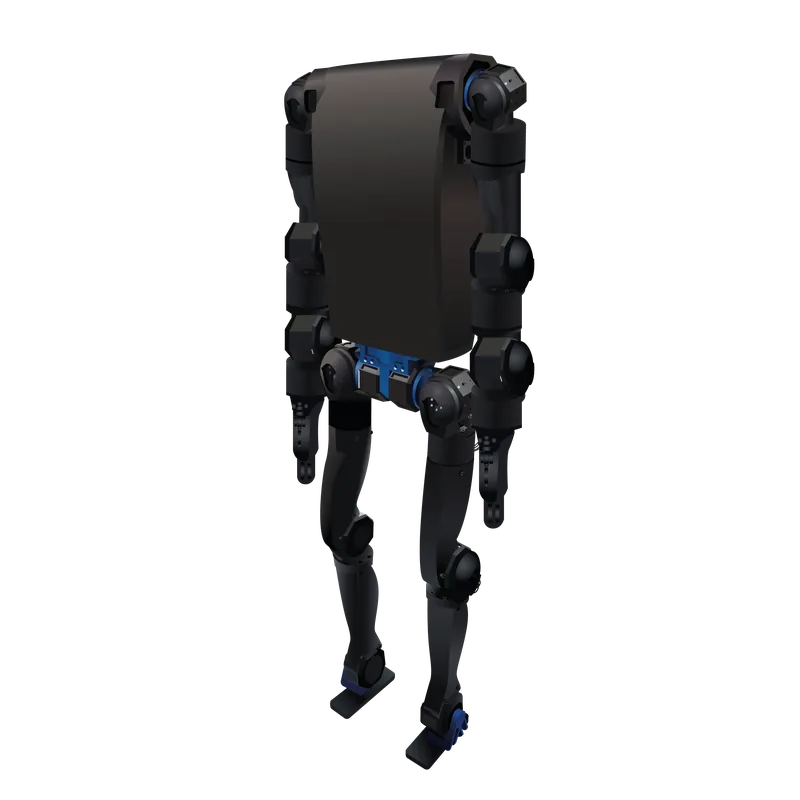
- Rocky’s 22 actuated joints comprise two waist, twelve leg and eight arm joints. Nominal standing height 1.58 m, pelvis 1.11 m and approximately 45 kg class are development-hardware specifications; standing height is not a complete body envelope.
- Rocky and sheet-metal Rocky Lite share 22 actuators, CM 5, 48 V battery andCAN architecture. Optional 20-DOF hand systems are separate add-ons and are not included in the 22-joint body count. Peak actuator torque/RPM and encoder bits are not walking speed, payload or accuracy.
- The manufacturer explicitly says it ships as development hardware with bring-up support; locomotion is the buyer’s research stack. The linked walking page is an in-browser MuJoCo simulation, not a live physical demonstration or proof that every failure mode is solved. Generic alternative bases are quoted project configurations, not additional named robots.
Product sources
- SuperDroid Robots — Rocky Biped Humanoid Robot | SuperDroid Robots · Manufacturer source · Checked 2026-11-02
Description
Full-size biped development hardware with 22 actuated body joints, nominal standing height around 1.58 m and approximately 45 kg class mass. CM 5 compute and open control interfaces support locomotion research; controllers require integration. Rocky Lite and separate optional hand systems do not alter the base body's joint count, and a browser walking simulation is not a physical livestream.
researchdev-platformprogrammablehumanoidbiped
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| WeightSource review · | Approximately 45 kg class, nominal development hardware |
| SizeSource review · | Approximately 1.58 m standing height; 1.11 m pelvis height; full footprint unestablished |
| Degrees of FreedomSource review · | 22 actuated joints: waist 2, legs 12, arms 8 |