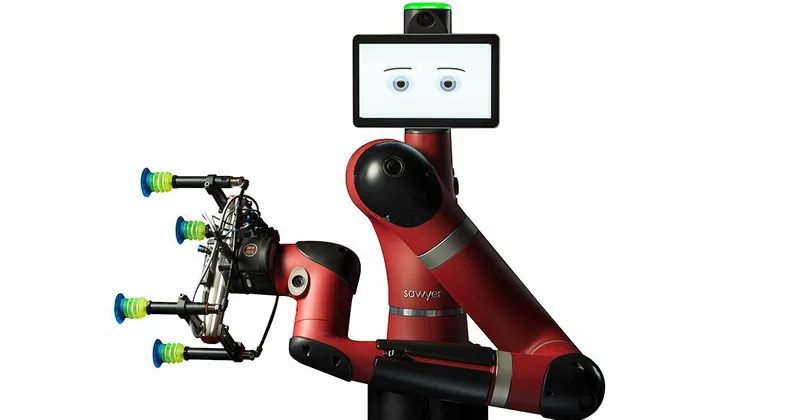
Description
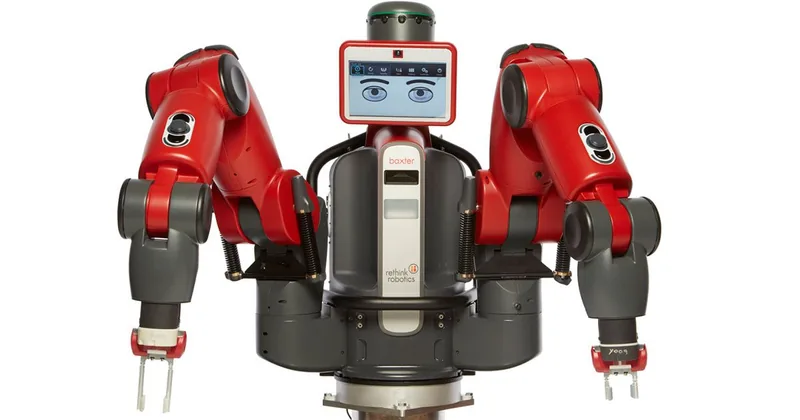
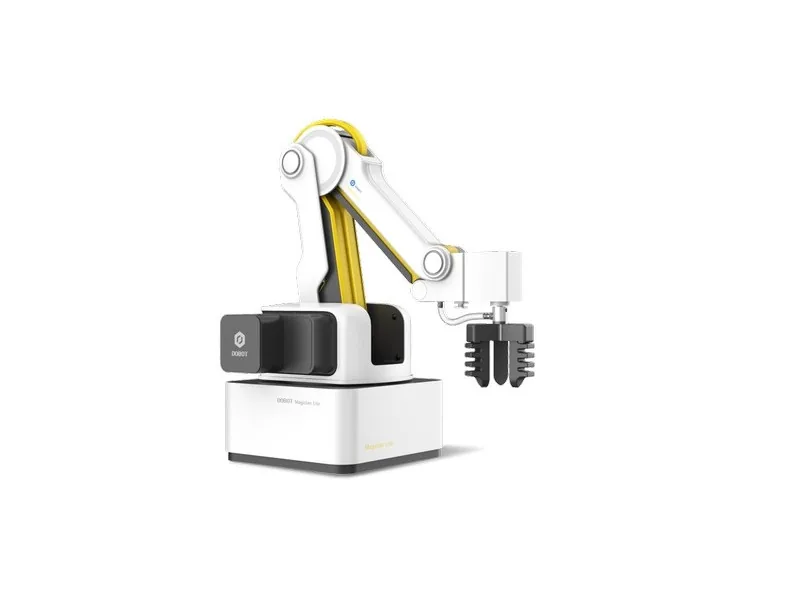
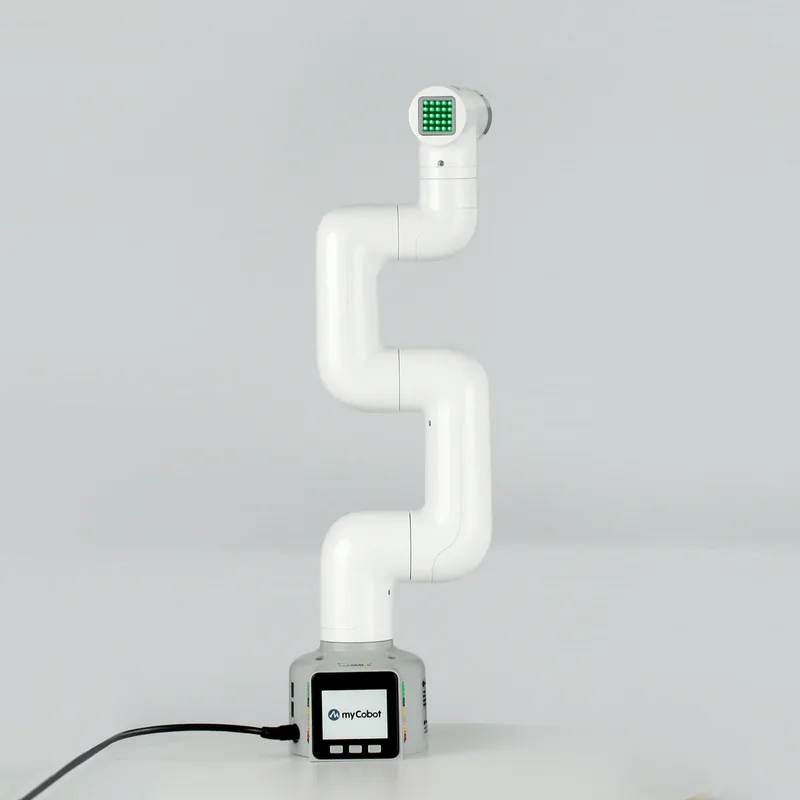
7-axis collaborative arm with joint torque sensing, integrated cameras and a ROS interface. Designed as a smaller, more precise successor to Baxter for machine tending and circuit-board testing.
cobotrobotic-armforce-sensingmachine-tendingrosindustrialresearch
Specifications
| Weight | 19 kg |
| Degrees of Freedom | 7 |
| Payload | 4 kg |
| Release Date | 2015 |