Product highlights
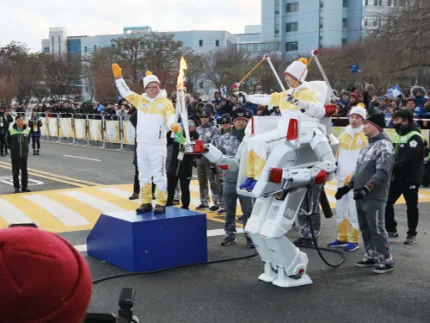
- KAIST’s developer report says the rider controlled FX-2 while it took several steps during the December 11, 2017 torch relay. Human-ridden control is distinct from the autonomous vehicle and other HUBO demonstrations described in the same event.
- The Korean government’s contemporaneous event report corroborates joint KAIST HUBO Lab/Rainbow Robotics development and says FX-2 was first revealed on December 11, 2017. The retained 2017 year is this historical public unveiling, not a retail availability or production milestone.
- The selected developer report does not establish exact mass, height, passenger payload, walking speed, battery endurance or a general public-riding safety approval. Current commercial availability remains unconfirmed.
Product sources
- KAIST — KAIST developer report, December 2017 torch relay · Developer source · Checked 2026-11-02
Description
FX-2 is the historical human-ridden walking robot controlled by a rider at KAIST’s December 11, 2017 Olympic torch relay. KAIST attributes development to Jun-Ho Oh; the Korean government’s event report corroborates joint HUBO Lab/Rainbow Robotics development and first unveiling that day. It is a research demonstration rather than an established autonomous humanoid or currently available passenger product.
prototyperesearchhuman-operatedrideable
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| PriceSource review · | Not disclosed |
| TerrainSource review · | KAIST campus riding demonstration; no rated terrain envelope |
| Release DateSource review · | 2017 |