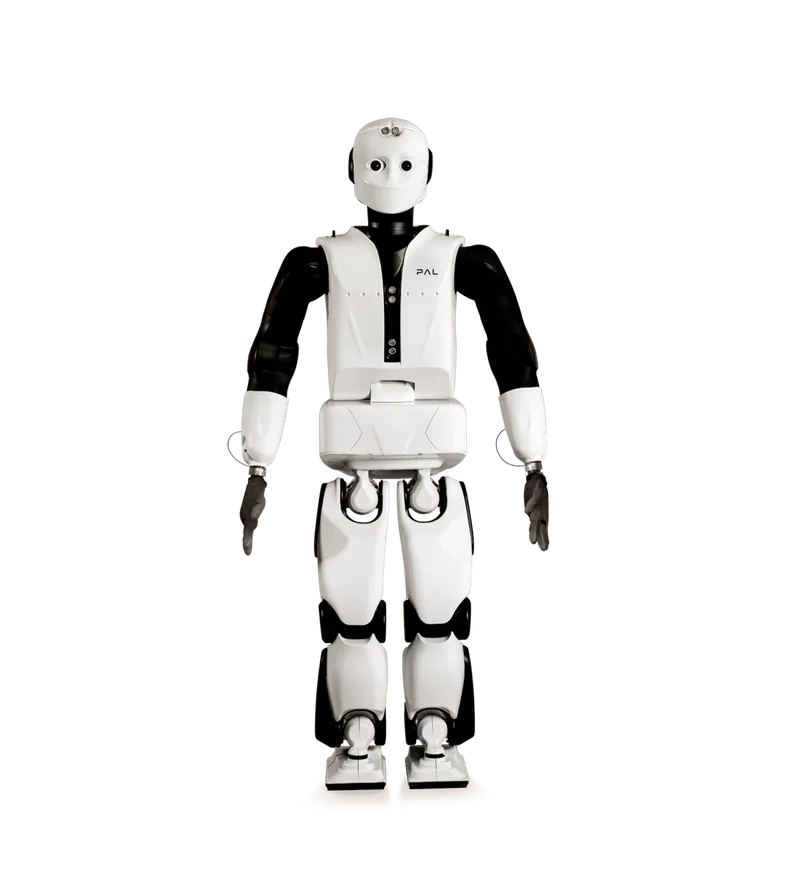
Product highlights
- The manufacturer table and datasheet give 175 cm, 95 kg and 6 kg per arm fully extended. The linked datasheet names 32 DoF; head and gripper hardware are configurable.
- Battery autonomy is 1.5 h walking versus 3 h standby. Standby is not three hours of walking or manipulation, and no complete recharge duration or verified travel-speed rating is established here.
- The torque-feedback footnote excludes head, wrists and grippers. Separate six-axis force/torque sensors are documented at wrists and ankles; the presence of those sensors does not make every joint torque-sensed.
- ROS/Orocos, ros_control, MoveIt and a URDF/Gazebo model support development. The webpage describes 2 kHz torque control and up-to-5 kHz network capability; network capability is not a universal measured control rate or safety certification.
Product sources
- PAL Robotics · Manufacturer source · Checked 2026-11-02
- PAL Robotics · Manufacturer source · Checked 2026-11-02
Description
Torque-controlled biped research platform with configurable head and grippers. The manufacturer documents 6 kg per arm at full extension, with different walking and standby endurance; the torque-sensor claim excludes head, wrists and grippers.
researchindustrialdev-platformprogrammable
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| PriceSource review · | Not disclosed |
| WeightSource review · | 95 kg |
| SizeSource review · | 175 cm high |
| Battery LifeSource review · | 1.5 h walking; 3 h standby |
| HandsSource review · | Configurable grippers; datasheet shows three fingers and one actuator |
| Degrees of FreedomSource review · | 32; manufacturer datasheet configuration |
| PayloadSource review · | 6 kg per arm at full extension |