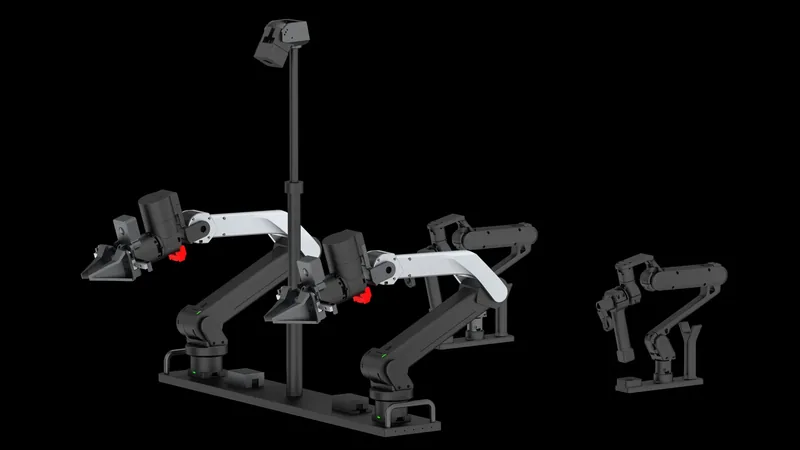
Product highlights
- Open-source seven-DOF arm platform provides CAD, firmware, control code and simulation tools for physical-AI research
- Backdrivable QDD joints and bilateral force feedback support contact-rich teleoperation and data collection
- Parallel gripper with an in-hand camera and CAN-FD control supports a modular research setup
- The company dates OpenArm 2.0 launch to May 2026; the March 2026 OpenArm 02 announcement and GTC Cell demonstration are earlier milestones. Its 1.0 upgrade changes the gripper, J5 bracket and covers while retaining the arm structure, motors and electronics.
- Nominal payload is 4.1 kg per arm held for one minute at maximum extension. Peak payload is 6.0 kg for a three-second move to that posture and a one-second hold. Both include the end effector: a 1.5 kg tool leaves 2.6 kg nominal and 4.5 kg peak for the object.
- The current homepage gives 633 mm reach, 5.5 kg mass per arm and 1 kHz CAN-FD control. Its 6500 USD bill-of-materials estimate is distinct from a complete installed system quotation and supplier listing prices.
- The redesigned compact parallel gripper carries an Arducam B0495 camera in each hand and replaceable fingers. Module resolution and lens field of view do not establish calibrated grasp precision or the effective view through the fingers, which the project explicitly leaves undocumented.
- The detailed motor page states that the DM4340 series is not QDD, qualifying broader project language about backdrivable QDD joints. Individual motor torque, rpm and voltage ratings are not whole-arm Cartesian speed, payload endurance or independent safety certification.
- Hardware is published under the strongly reciprocal CERN-OHL-S-2.0 license; software repositories have their own licenses. Open source does not mean every asset has a permissive license. The manufacturer directory distinguishes evaluated suppliers and warns that unassessed copies may be incompatible.
Product sources
- OpenArm — version 2.0 payload definitions · Manufacturer source · Checked 2026-11-03
- Enactic — OpenArm 2.0 homepage and KER preview · Manufacturer source · Checked 2026-11-03
- OpenArm — current 2.0 project overview · Manufacturer source · Checked 2026-11-03
- OpenArm — 2.0 gripper and in-hand camera · Manufacturer source · Checked 2026-11-03
- OpenArm — 2.0 motor selection and component limits · Manufacturer source · Checked 2026-11-03
- OpenArm — official 1.0 to 2.0 upgrade boundaries · Manufacturer source · Checked 2026-11-03
- OpenArm — project manufacturer directory and attributed prices · Manufacturer source · Checked 2026-11-03
- Enactic — company portfolio and dated launch milestones · Manufacturer source · Checked 2026-11-03
- Enactic — hardware assemblies and CERN-OHL-S-2.0 license · Manufacturer source · Checked 2026-11-03
Description
OpenArm 2.0 is Enactic’s open-source seven-DOF-per-arm platform for physical-AI research, teleoperation and reproducible evaluation. The company dates its launch to May 2026. A compact camera-equipped gripper and changed J5 bracket distinguish it from 1.0, while the upgrade guide retains arm structure, motors and electronics. Reach and mass are per arm; payload ratings include the end effector and depend on short specified tests. Hardware and software use different licenses.
researchdev-platformopen-sourceprogrammableteleoperated
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| PriceSource review · | Project manufacturer directory lists WowRobo V2 from 6500 USD; configuration, shipping and supplier terms vary |
| WeightSource review · | 5.5 kg per arm; manufacturer homepage, not complete bimanual installation mass |
| Arm reachSource review · | 633 mm per arm; manufacturer homepage reach, not full Cell workspace |
| HandsSource review · | Compact parallel gripper with one in-hand camera per arm and replaceable fingers |
| Degrees of FreedomSource review · | 7 per arm; gripper and full installation axis count separate |
| PayloadSource review · | 4.1 kg nominal per arm for 1 minute at full extension; 6.0 kg peak for 3-second move and 1-second hold; includes end effector |
| TerrainSource review · | Fixed research installation on a secured table/base; no mobile terrain rating established |
| Release DateSource review · | 2026 |