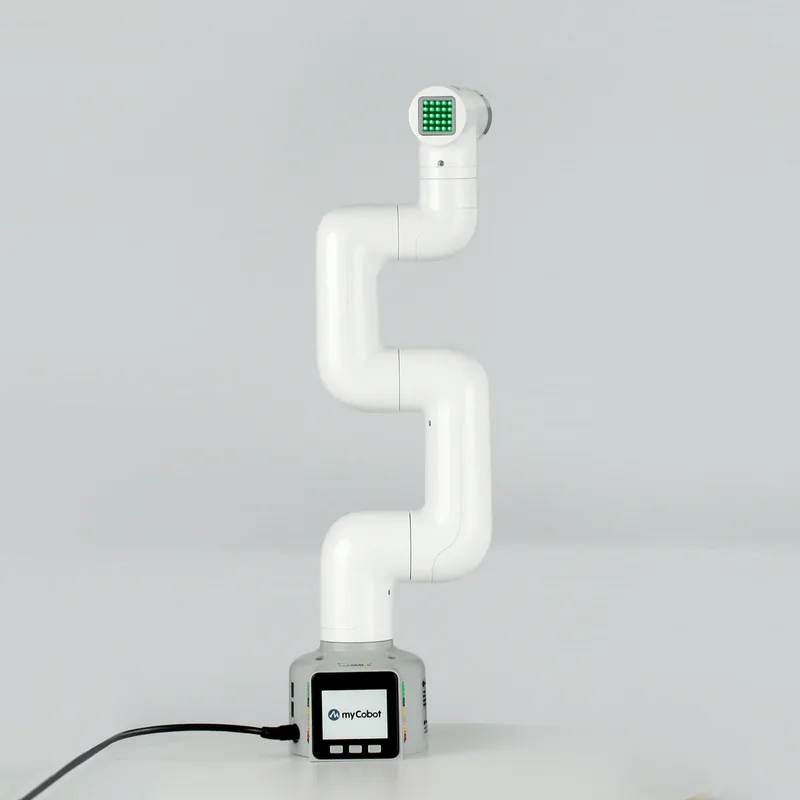
Product highlights
- The exact Mercury A1 specification table lists 7 degrees of freedom, 3.5 kg net mass and 98 x 128 x 640 mm. Product dimensions are not a complete swept working envelope.
- The A1 has seven harmonic joints, carbon-fiber-based construction and a 450 mm working radius. myPanel on the two-inch touchscreen supports local teaching; joint torque/encoder claims are not whole-arm positioning guarantees.
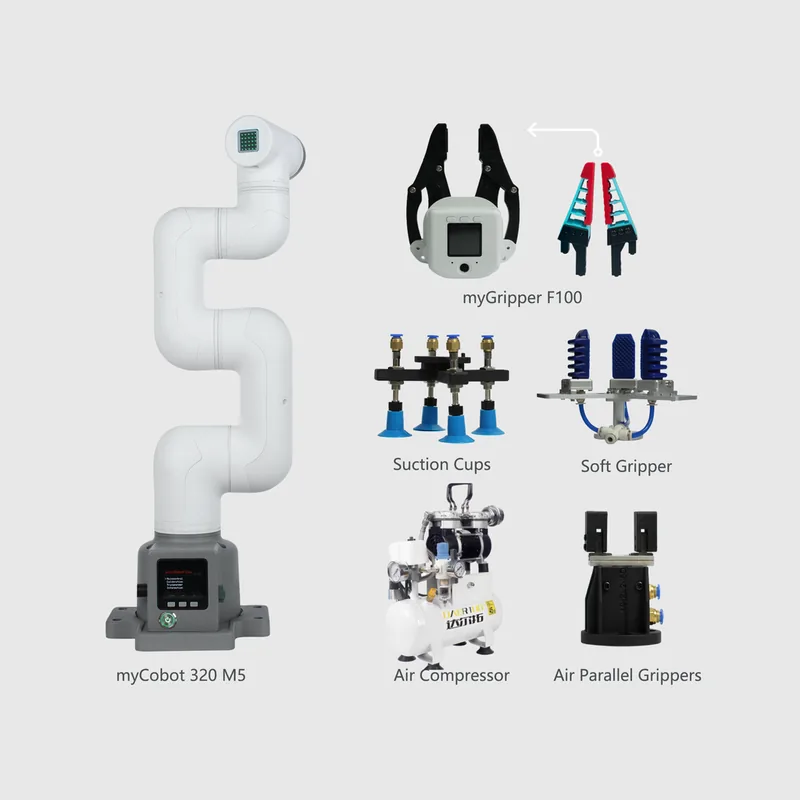
- Python/C++ interfaces and ROS, MoveIt, Gazebo and MuJoCo resources support research integration. VR/exoskeleton teleoperation, grippers, suction pumps and vision combinations require the relevant equipment; a demonstration is not a turnkey autonomous task guarantee.
Product sources
- Elephant Robotics — mercury-specifications-en · Manufacturer source · Checked 2026-11-02
- Elephant Robotics — mercury-a1-en · Manufacturer source · Checked 2026-11-02
Description
Mercury A1 is a seven-axis harmonic-joint research arm with a 450 mm working radius and built-in myPanel teaching interface.
researchdev-platformprogrammablecobot
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| PriceSource review · | Not disclosed |
| WeightSource review · | 3.5 kg |
| SizeSource review · | 98 x 128 x 640 mm |
| Arm reachSource review · | 450 mm |
| Degrees of FreedomSource review · | 7 |
| PayloadSource review · | 1 kg |