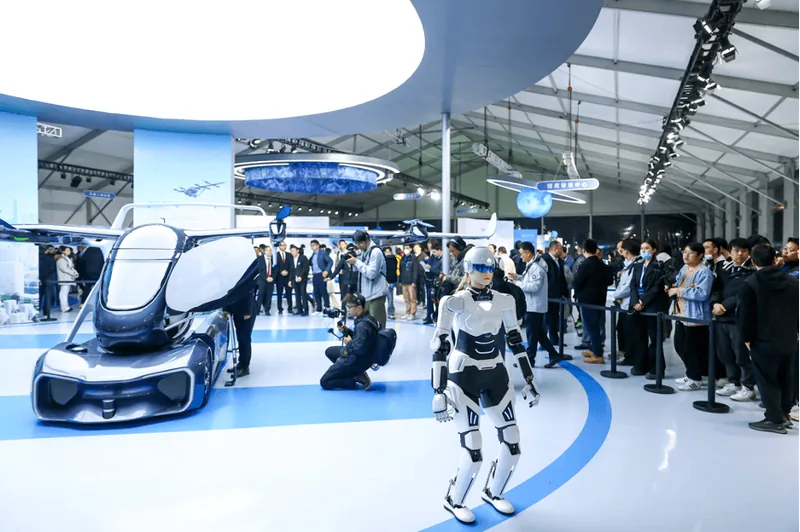
Product highlights
- The Standard joint guide specifies 21 joints, full-body command indices 0–20 and upper-body indices 0–8. It explicitly has no neck joints; the Pro 31-joint structure is not inherited.
- The Standard package has its own real-robot and simulation guides. Its state machine currently provides AMP control; the documented Mimic deployment is implemented in the Pro package, not established as an identical Standard capability.
- SDK process location and target are independent: a host-side program can control real hardware when the required ROS/DDS network is available. Simulation success alone is not physical deployment certification.
- The battery guide describes a 72 V / 5 A external output, up to 360 W, as open on Standard and not open on Pro. This is external power output, not battery capacity, charger input or a recharge-time rating.
- Complete robot mass, full standing size, arm reach, payload, travel speed, ingress protection, endurance, charging time and first-release year are not established in the reviewed exact-variant text; generic or legacy values are not inherited.
Product sources
- DEEP Robotics — DR02 Standard · Manufacturer source · Checked 2026-11-02
- DEEP Robotics — DR02 Standard joint array and control limits · Manufacturer source · Checked 2026-11-02
- DEEP Robotics — Standard/Pro external-output distinction · Manufacturer source · Checked 2026-11-02
Description
Named humanoid configuration with a dedicated manufacturer ROS 2 package and joint-control guide. Physical ratings remain separate from software control ranges, simulation models and optional upper-body workflows.
researchindustrialdev-platform
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| PriceSource review · | Not disclosed |
| Degrees of FreedomSource review · | 21 joints; no neck joints |