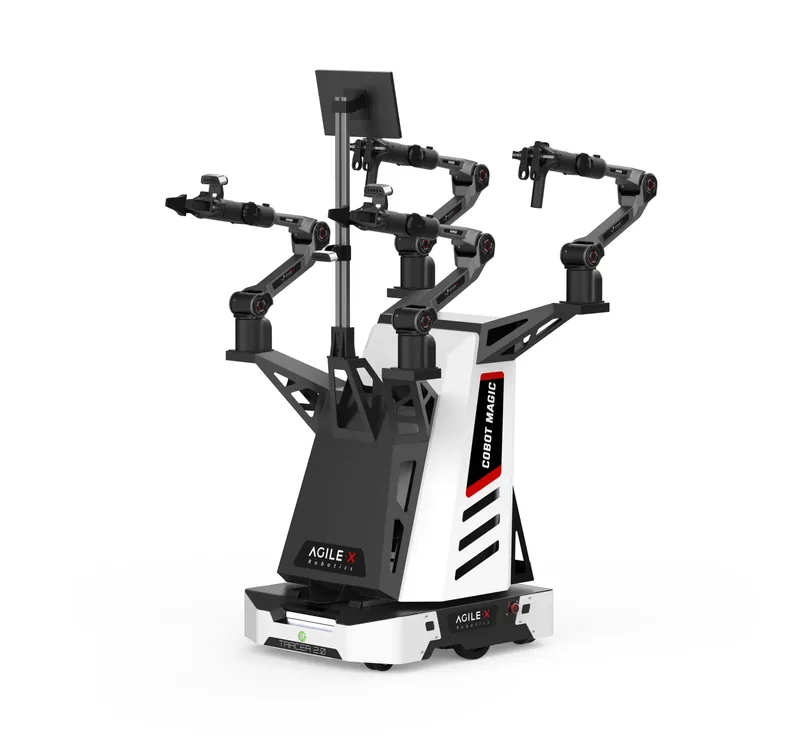
Description
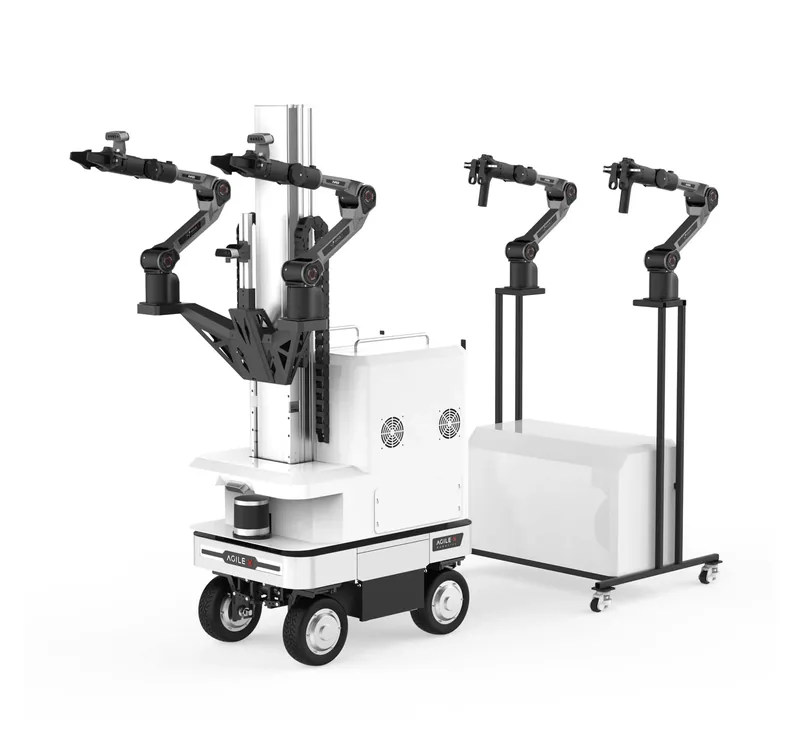
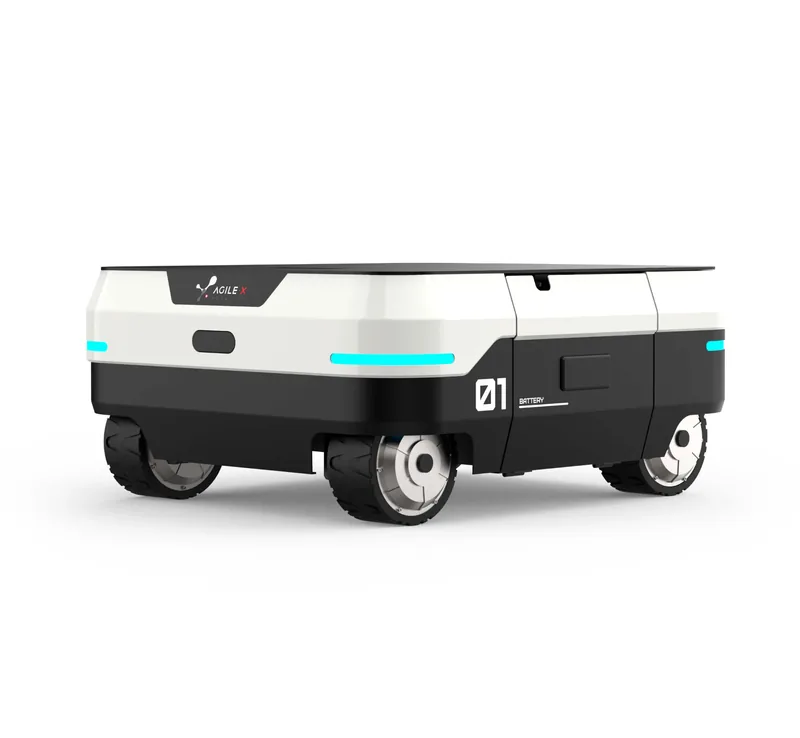
Open-source whole-body teleoperation platform from AgileX Robotics (松灵机器人) based on Stanford's Mobile ALOHA architecture. It combines a TRACER 2.0 mobile base with four 6-DOF PiPER arms (two leader, two follower), wrist and top-view cameras and an onboard PC for bimanual manipulation, demonstration-data collection and VLA model training.
researchdual-armmobile-manipulatordata-collectionteleoperationopen-sourceembodied-aidev-platformros
Specifications
| Hands | two-finger grippers |
| Release Date | 2024 |