Product highlights
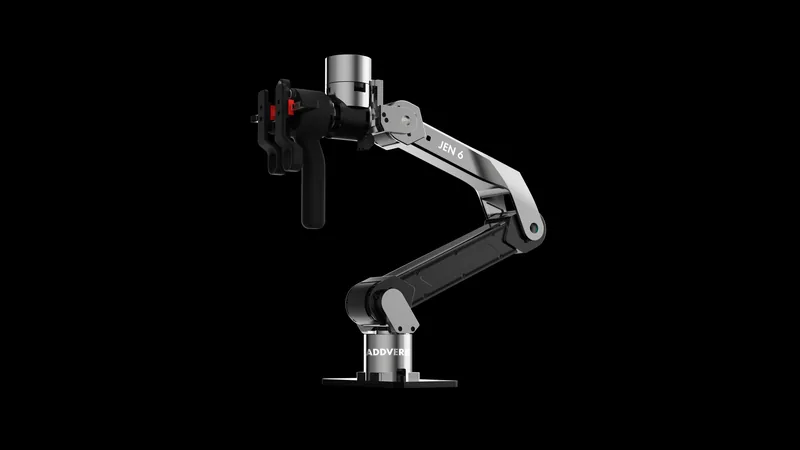
- The selected Syncro 10 state specifies 10 kg payload,1300 mm reach,40 kg arm mass and six degrees of freedom. The separate controller is10kg and400×400×210mm; controller size is not arm body size.
- Maximum tool-center-point speed is 2.4 m/s and position repeatability ±0.1 mm. Angular/joint velocity,base localization and docking are different measurements; no arm-repeatability claim becomes navigation accuracy.
- The page lists 2000 W maximum power,220 VAC input,IP54 and a 160 mm mounting footprint. Footprint is not a full swept-envelope or complete arm dimension. Tool-flange24V/2A output is not arm payload.
- Open Python/C++ SDK,ROS2 and developer controls are documented; GPU devices,vision,haptics,grippers and other integrations depend on configuration. Standards/CE language does not independently certify a completed collaborative cell.
Product sources
- Addverb — Syncro 10 · Manufacturer source · Checked 2026-11-02
- Addverb — Syncro5/10 payload and reach comparison · Manufacturer source · Checked 2026-11-02
Description
Six-axis collaborative arm with open developer interfaces and configuration-dependent tooling. Arm mass and controller dimensions remain separate.
commercialindustrialresearchdev-platform
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| PriceSource review · | Not disclosed |
| WeightSource review · | 40 kg arm only |
| Arm reachSource review · | 1300 mm |
| Degrees of FreedomSource review · | 6 |
| PayloadSource review · | 10 kg |
| SpeedSource review · | 2.4 m/s maximum TCP |
| IP RatingSource review · | IP54 |