Product highlights
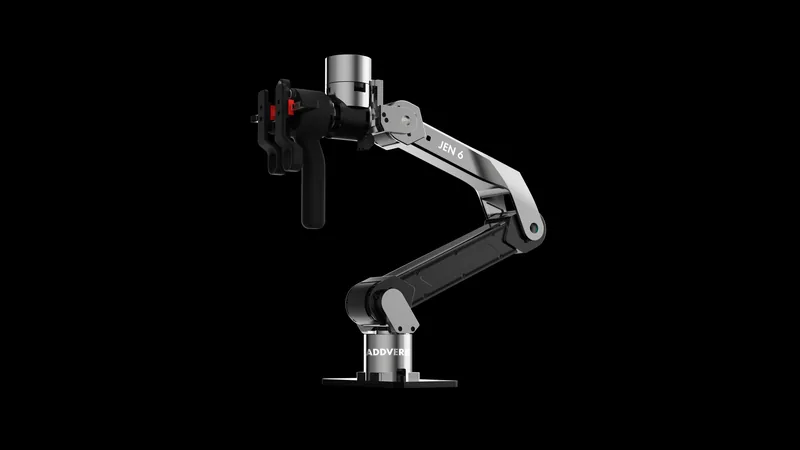
- The named manipulator table gives3.75kg mass,650mm reach and six arm joints plus one gripper. Its55mm gripper range is not arm reach; joint operational/peak torques and radian-per-second speeds remain joint-level values.
- Leader/follower teleoperation,250Hz communication,data logging and Python/ROS2/C++ interfaces support learning workflows. A paired leader/follower kit is an integration option,not automatically included twice as many arms.
- The same page contains a copied blurb calling Jen-6 a heavy-duty quadruped with20kg carry. That contradicts the page identity and is not accepted as manipulator payload or a new quadruped model. No exact arm payload,IP rating or whole-system power/battery duration is established.
- The gripper table gives3Nm operational and9Nm peak torque; arm joints give other values. Torque,gripper opening and peak angular speed are not kilograms of payload or translational TCP speed.
Product sources
- Addverb — JEN 6 · Manufacturer source · Checked 2026-11-02
Description
Quasi-direct-drive manipulator for leader/follower teleoperation,data collection and robot learning. Copied quadruped marketing text is not accepted as arm load data.
commercialindustrialresearchdev-platform
Specifications
Sources cover the marked fields only. Unmarked values have not been checked in this review; manufacturer figures are not independent test results.
| PriceSource review · | Not disclosed |
| WeightSource review · | 3.75 kg |
| Arm reachSource review · | 650 mm |
| HandsSource review · | Gripper; 55 mm range of motion |
| Degrees of FreedomSource review · | 6 + 1 gripper |